XGO-Duck: A Robot Duck That Learned to Walk
Meet XGO-Duck by Luwu Dynamics: 15 servos, neural locomotion, and Arduino UNO Q—ready for you to build, hack, and explore.
Devices & Components

Arduino® UNO™ Q 2GB
Luwu Dynamics XGO-Duck Expansion Board
Feetech HD1910M Serial Bus Servo
10 × 15 × 3 mm Bearing
M2 × 6 Countersunk Self-Tapping Screw, Flat End (pack of 200)
16 × 22 × 4 mm Bearing
XGO-Duck 3D-Printed Parts (1 set)
AMP2.0 3-Pin Servo Cable
M3 × 16 Round-Head Machine Screw
M2.3 × 8 Flat-Top Round-Head Self-Tapping Screw, Flat End
Hardware & Tools
Robot Support Stand
Flush Cutters / Deburring Tool
Digital Multimeter (voltage and continuity checks)
Precision Screwdriver Set
FDM 3D Printer (optional if parts are outsourced)
Software & Tools
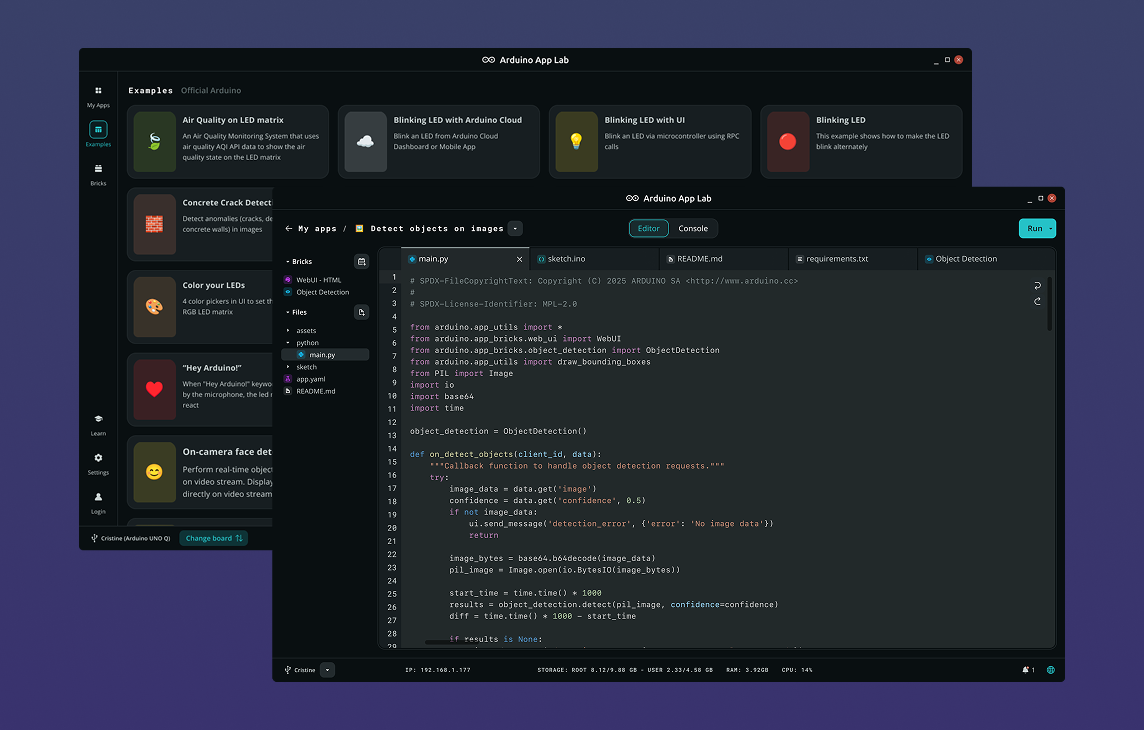
Arduino App Lab
Web Browser (setup, calibration, and control)
Bambu Studio (3D printing preparation)
Project description
Code
XGO-Duck Runtime for Arduino UNO Q
Runtime, included motion policies, and browser tools for servo setup, calibration, and control.


Arduino App Lab
XGO Duck
XGO Duck on Arduino Uno Q, based on Microduck. Linux runs ONNX policies at 50 Hz; the STM32 drives 15 servos and a QMI8658 at 100 Hz.
XGO Duck
Comments
Only logged in users can leave comments